| #include <Servo.h> |
| //defining Servos |
| Servo servohori; |
| int servoh = 0; |
| int servohLimitHigh = 160; |
| int servohLimitLow = 20; |
| |
| Servo servoverti; |
| int servov = 0; |
| int servovLimitHigh = 160; |
| int servovLimitLow = 20; |
| //Assigning LDRs |
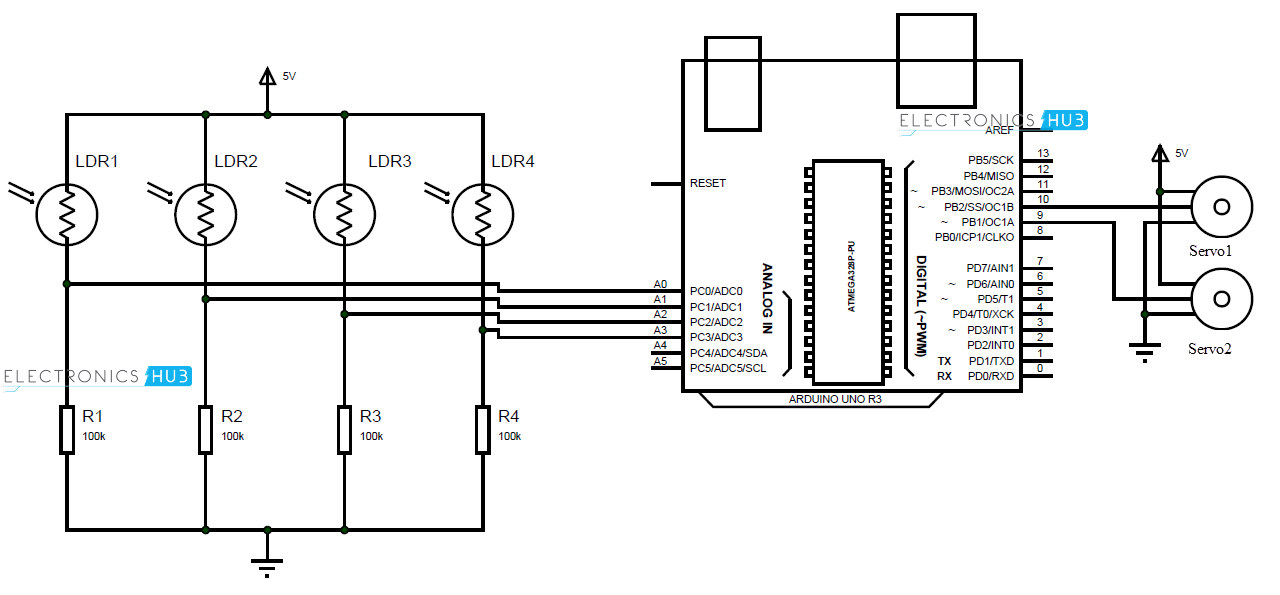
| int ldrtopl = 2; //top left LDR green |
| int ldrtopr = 1; //top right LDR yellow |
| int ldrbotl = 3; // bottom left LDR blue |
| int ldrbotr = 0; // bottom right LDR orange |
| |
| void setup () |
| { |
| servohori.attach(10); |
| servohori.write(0); |
| servoverti.attach(9); |
| servoverti.write(0); |
| delay(500); |
| } |
| |
| void loop() |
| { |
| servoh = servohori.read(); |
| servov = servoverti.read(); |
| //capturing analog values of each LDR |
| int topl = analogRead(ldrtopl); |
| int topr = analogRead(ldrtopr); |
| int botl = analogRead(ldrbotl); |
| int botr = analogRead(ldrbotr); |
| // calculating average |
| int avgtop = (topl + topr) / 2; //average of top LDRs |
| int avgbot = (botl + botr) / 2; //average of bottom LDRs |
| int avgleft = (topl + botl) / 2; //average of left LDRs |
| int avgright = (topr + botr) / 2; //average of right LDRs |
| |
| if (avgtop < avgbot) |
| { |
| servoverti.write(servov +1); |
| if (servov > servovLimitHigh) |
| { |
| servov = servovLimitHigh; |
| } |
| delay(10); |
| } |
| else if (avgbot < avgtop) |
| { |
| servoverti.write(servov -1); |
| if (servov < servovLimitLow) |
| { |
| servov = servovLimitLow; |
| } |
| delay(10); |
| } |
| else |
| { |
| servoverti.write(servov); |
| } |
| |
| if (avgleft > avgright) |
| { |
| servohori.write(servoh +1); |
| if (servoh > servohLimitHigh) |
| { |
| servoh = servohLimitHigh; |
| } |
| delay(10); |
| } |
| else if (avgright > avgleft) |
| { |
| servohori.write(servoh -1); |
| if (servoh < servohLimitLow) |
| { |
| servoh = servohLimitLow; |
| } |
| delay(10); |
| } |
| else |
| { |
| servohori.write(servoh); |
| } |
| delay(50); |
| } |